My Robotic Dog Finally Has a Name: Fox
My robotic dog finally has a name: Fox. 🐕🤖
And this name means more to me than just another project name.
Fox was the name of the last dog I raised at home.
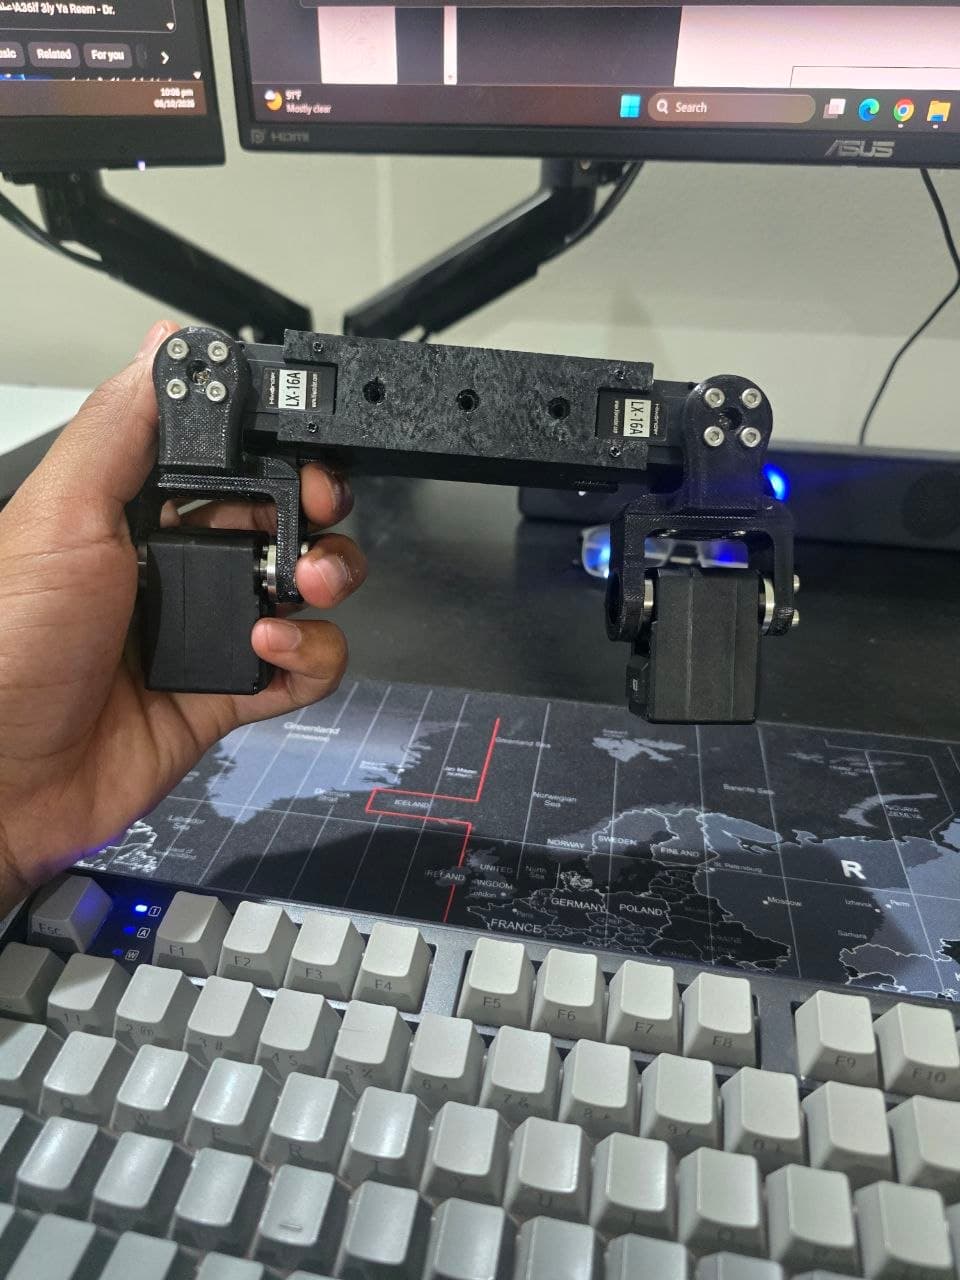
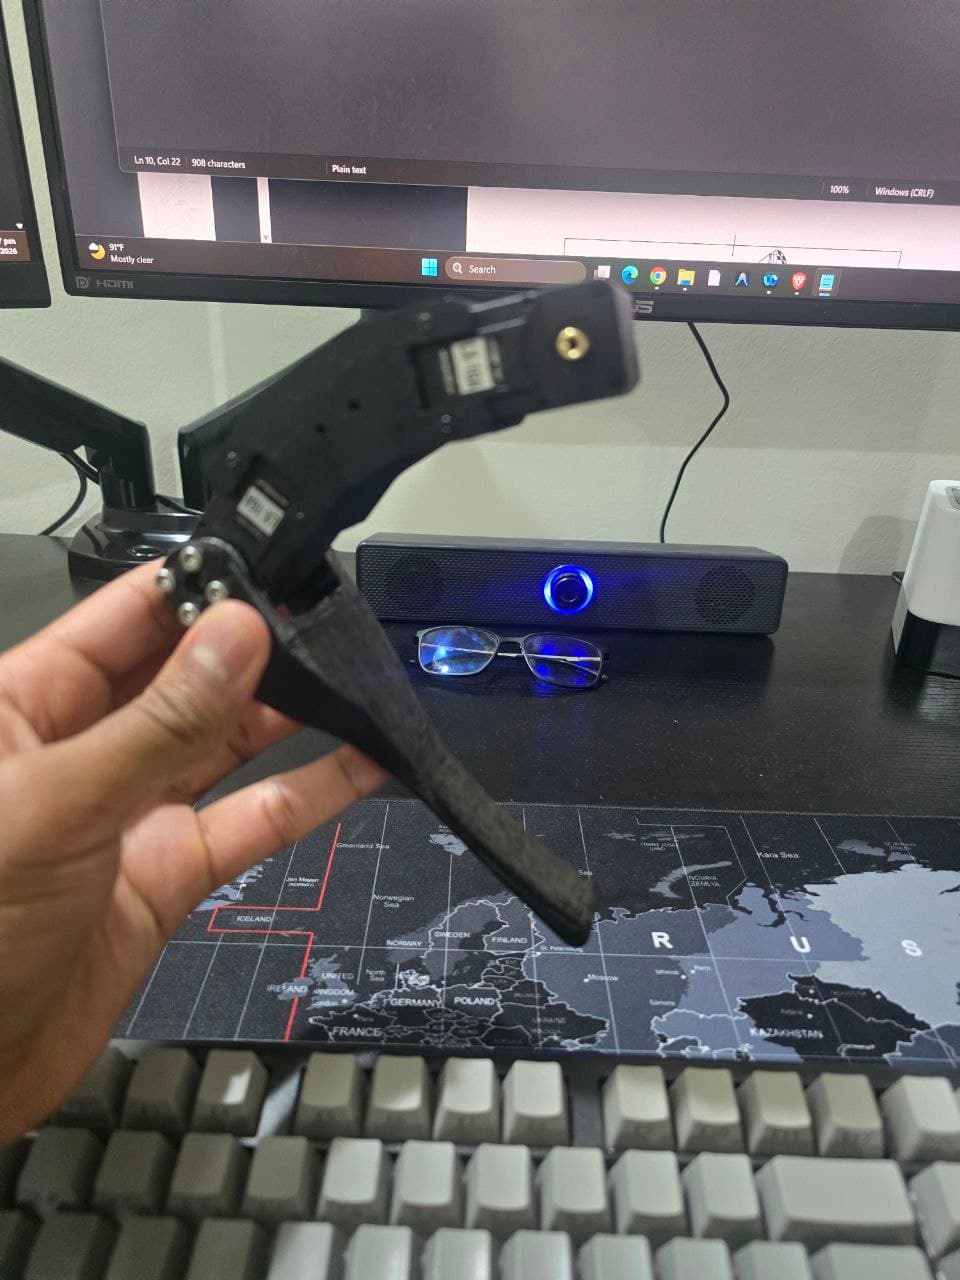
Now, after completing the 3D design, printing the mechanical parts, and waiting for weeks...
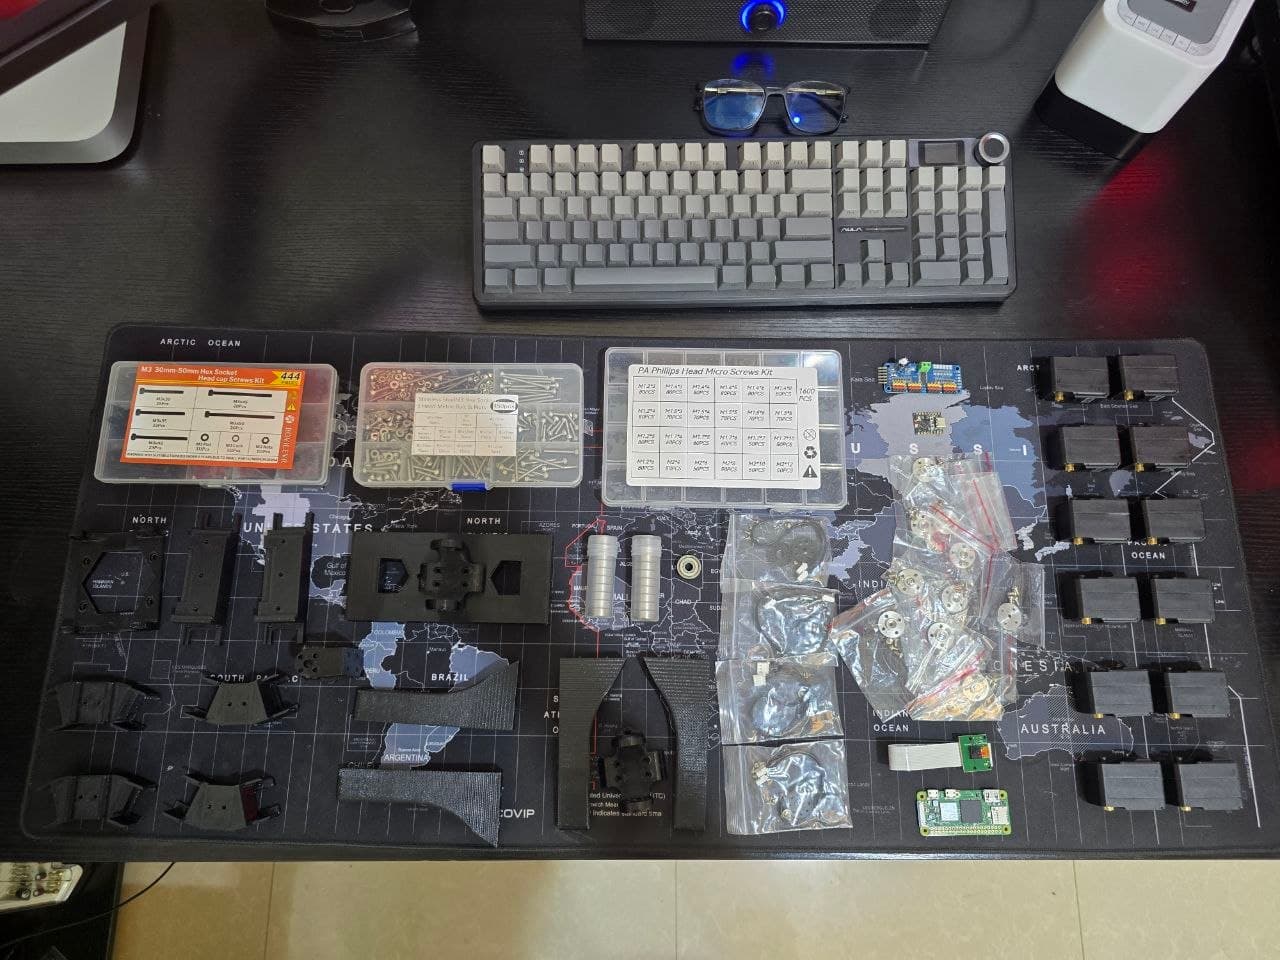
All the components have finally arrived. It’s time to bring Fox to life.
But I’m deliberately NOT starting with AI.
I believe intelligence means nothing if the body itself isn’t mature enough.
Phase 1: Build the Body 🦾
My first goal is to perfect Fox’s mechanical capabilities.
With 12 degrees of freedom, I want him to be able to:
→ Walk naturally
→ Sit and lay down
→ Wave hello 👋
→ Maintain balance
→ Move his joints smoothly
→ And eventually… jump.
Only when the mechanical system becomes reliable will I move to the part I’m most excited about:
Phase 2: Give Fox a Soul. 🧠
That’s when the Raspberry Pi, camera, sensors, and AI will come together.
I want Fox to have:
👀 Eyes — to understand what’s around him.
👂 Ears — to listen and recognize commands.
🧠 A brain — to reason and make decisions.
🐕 Behavior — to react naturally to his environment.
The goal isn't simply to build a robot that executes commands.
I want to build a robotic companion that can perceive, understand, react, and eventually learn.
What’s inside Fox?
🧠 Raspberry Pi — the main brain
📷 Raspberry Pi Camera — vision
⚙️ 12× LX-16A full-metal serial bus servos — 12 DOF joints
🎛️ Serial Bus Servo Controller — servo communication and control
🔩 12× 626ZZ bearings — smoother joint movement
🦾 12× metal servo horns
🔧 M3 DIN/ISO screws and nuts in multiple sizes for the mechanical assembly
The parts are here.
The design is ready.
The printed body is waiting.
Now the real engineering begins.
Next milestone: assembling Fox and making those 12 joints move together for the first time. 🐕⚙️
I’ll share the successes, failures, calculations, mechanical challenges, and code as Fox slowly comes to life.
From printed parts → movement → intelligence → personality.
Welcome to the journey, Fox. 🦊🤖